Direct drive
No gearbox, no belt, no ballscrew — what that removes from the load path, and what it asks of the motor instead.
Portal Development Kit (PDK): this is a development kit. Supplied as a kit of parts to developers, integrators, researchers and B2B partners for evaluation and development, and assembled by the recipient. Not a finished consumer product, not offered for consumer sale; nothing on this site is a safety certification or a performance guarantee.
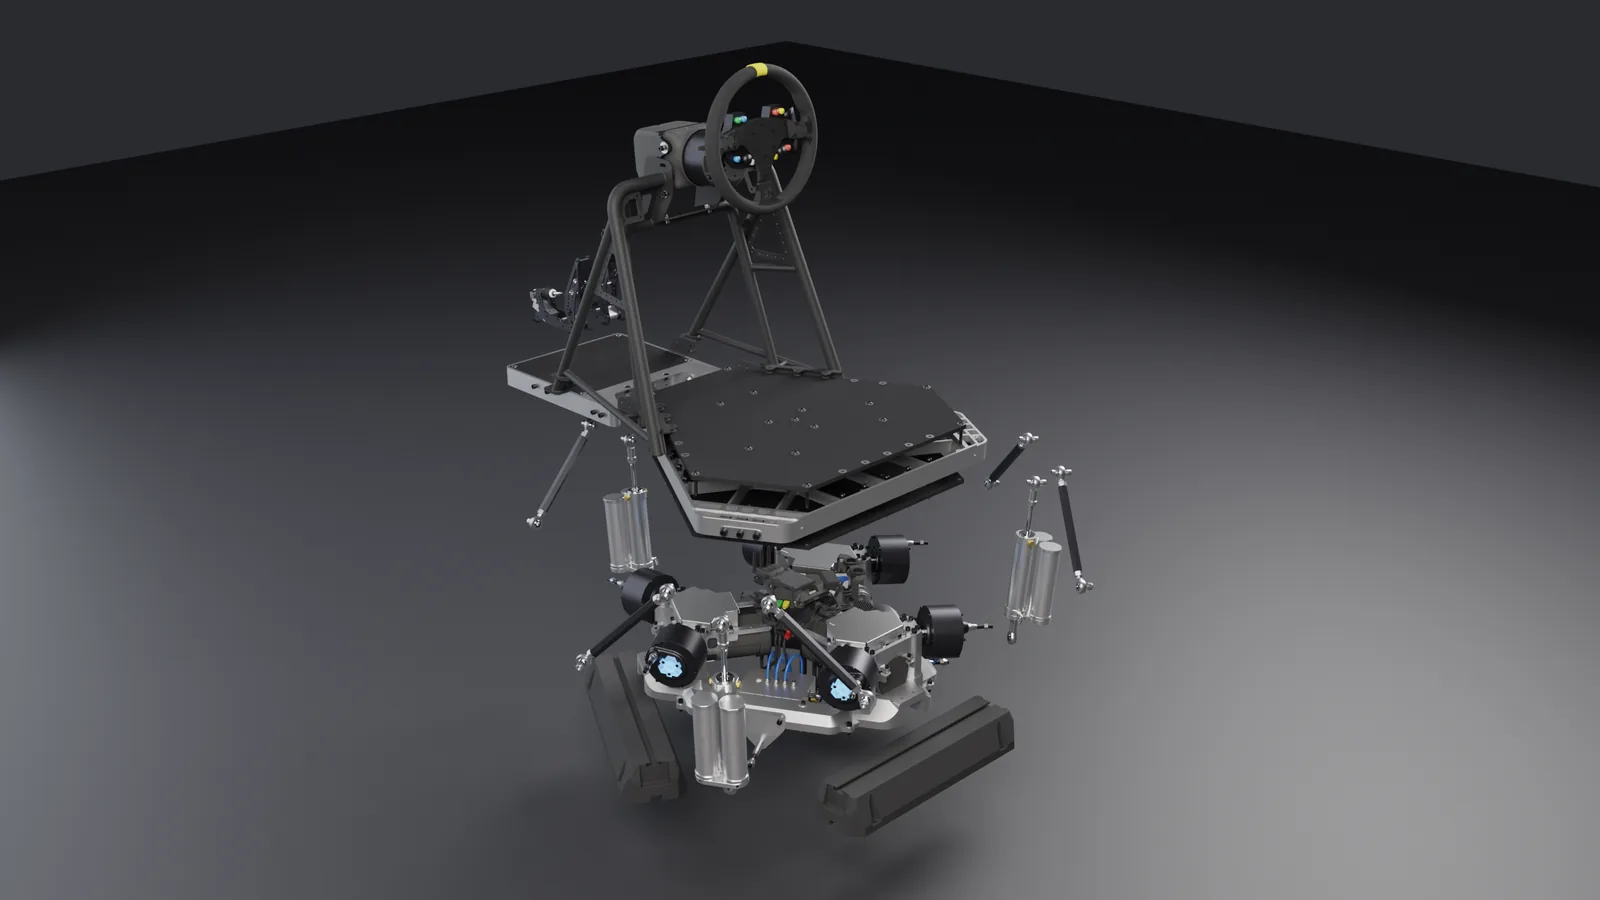
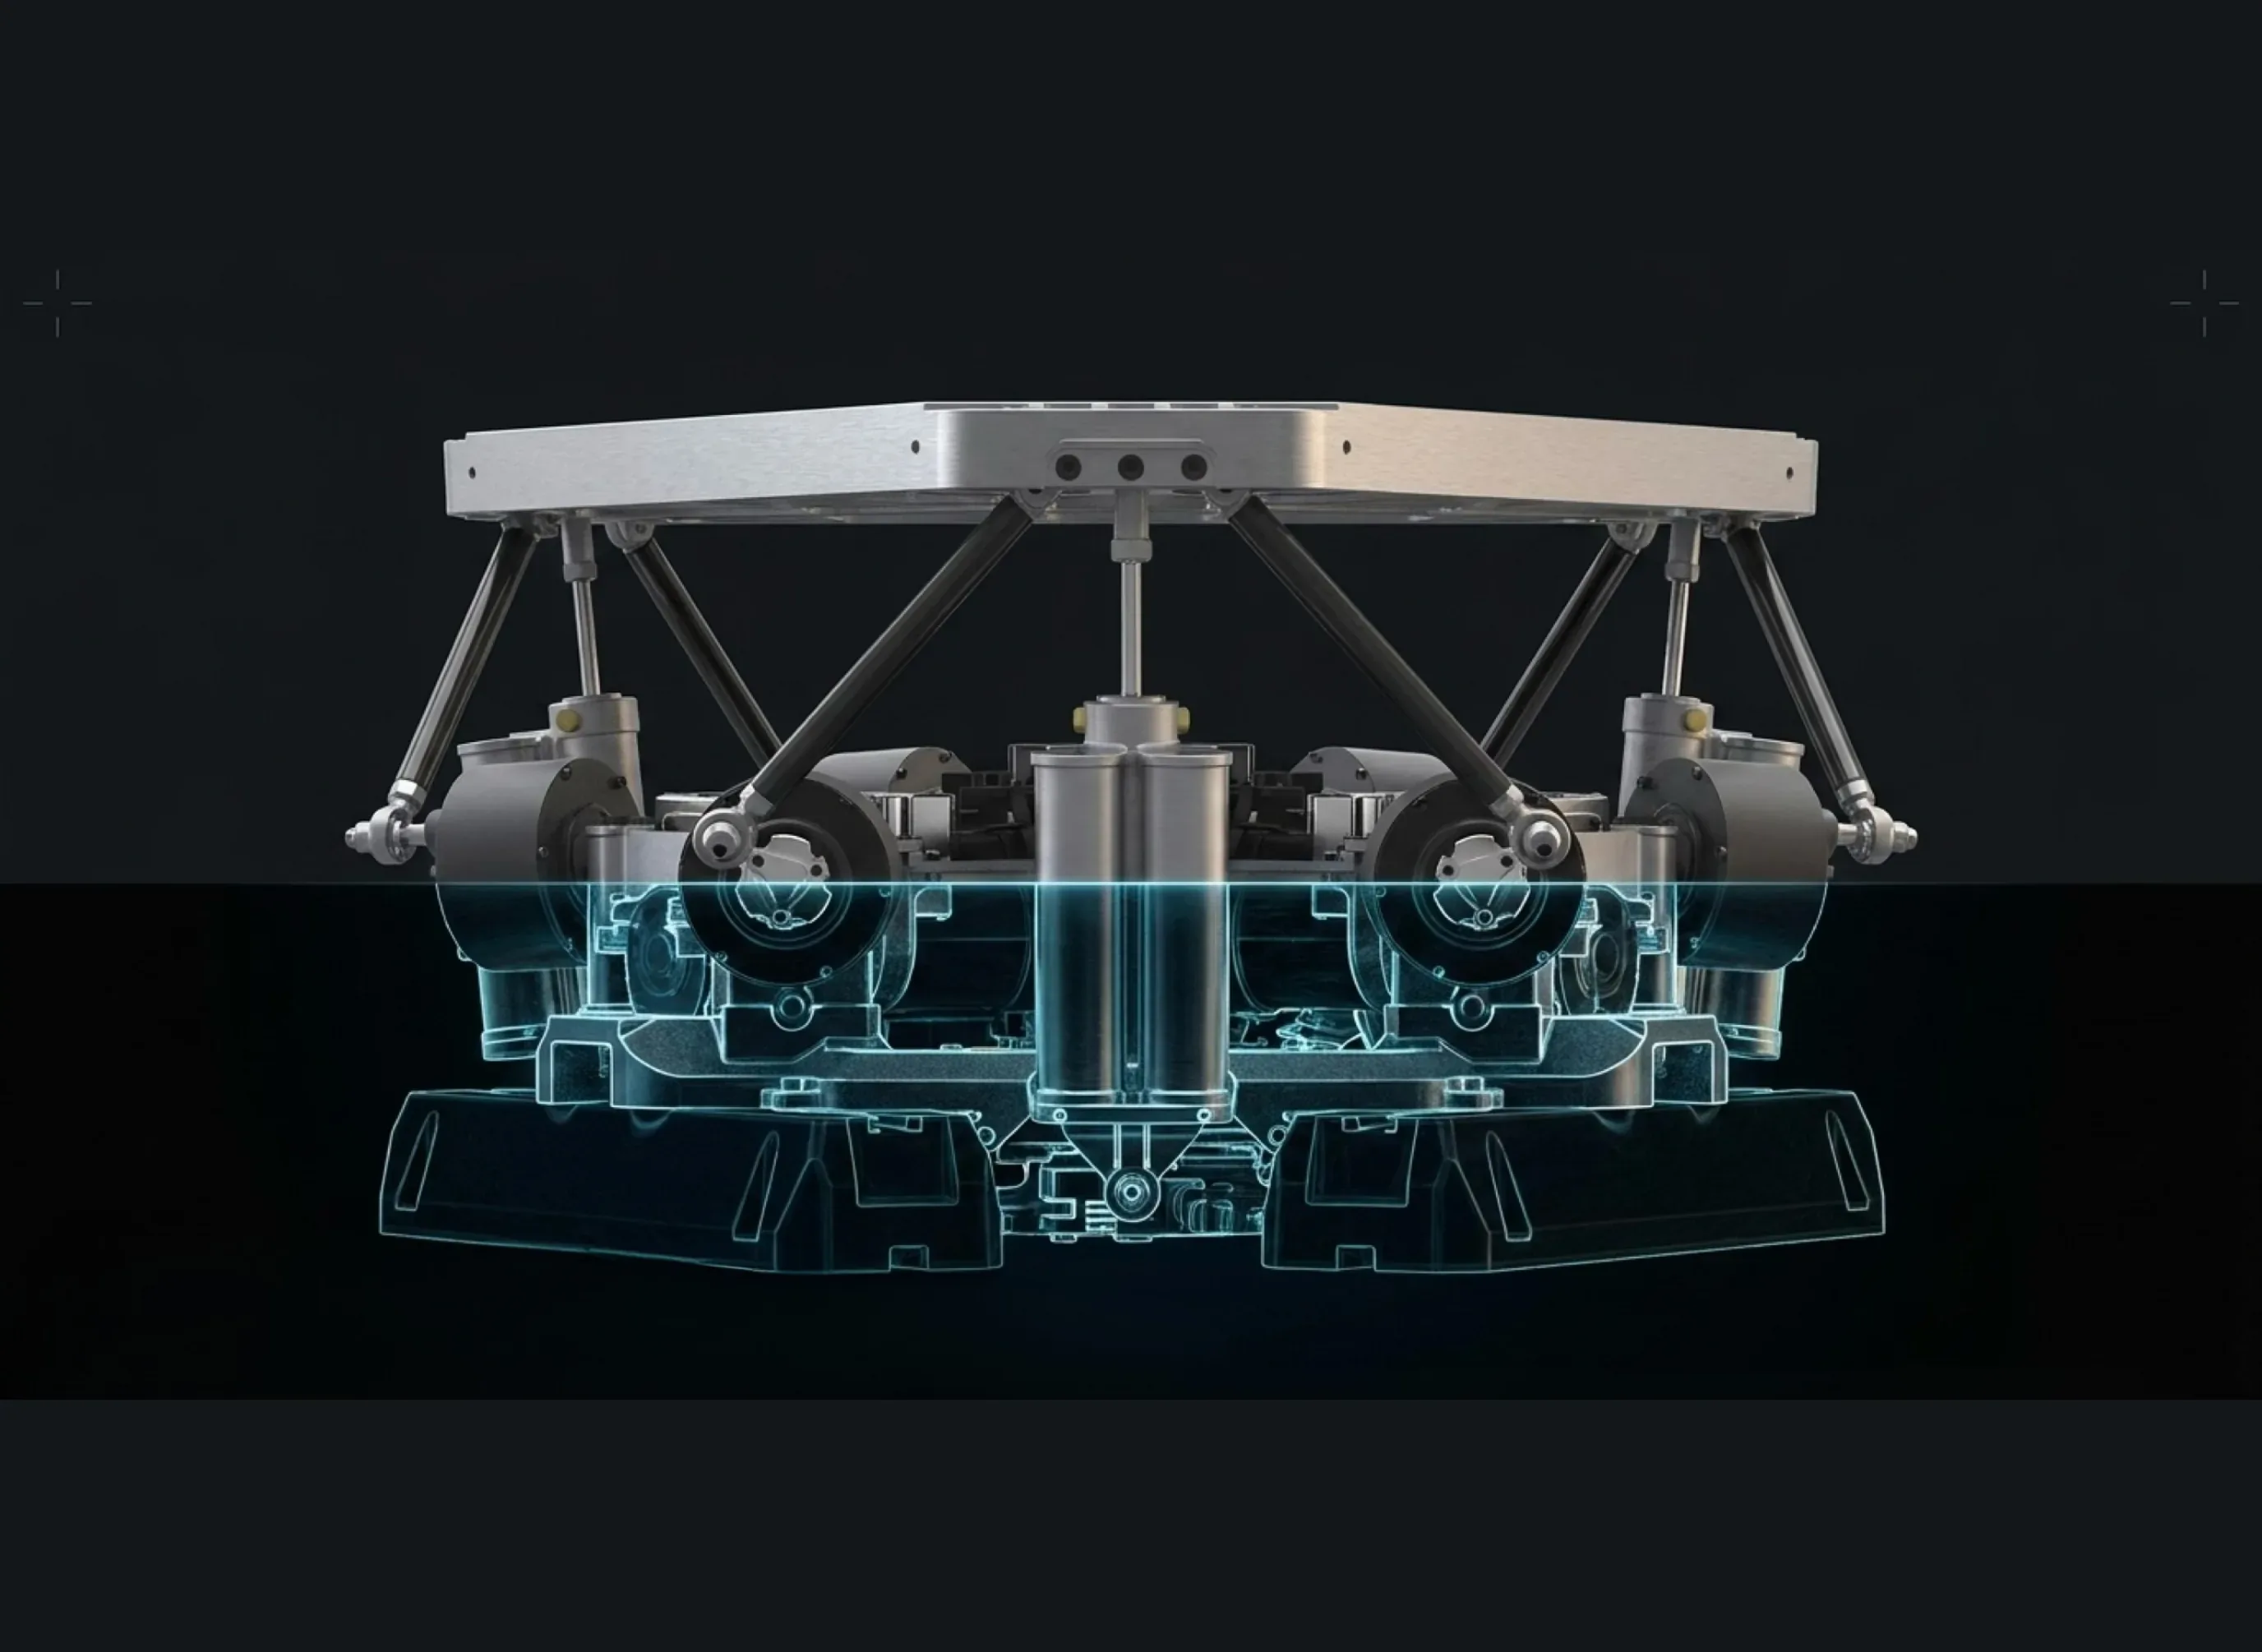
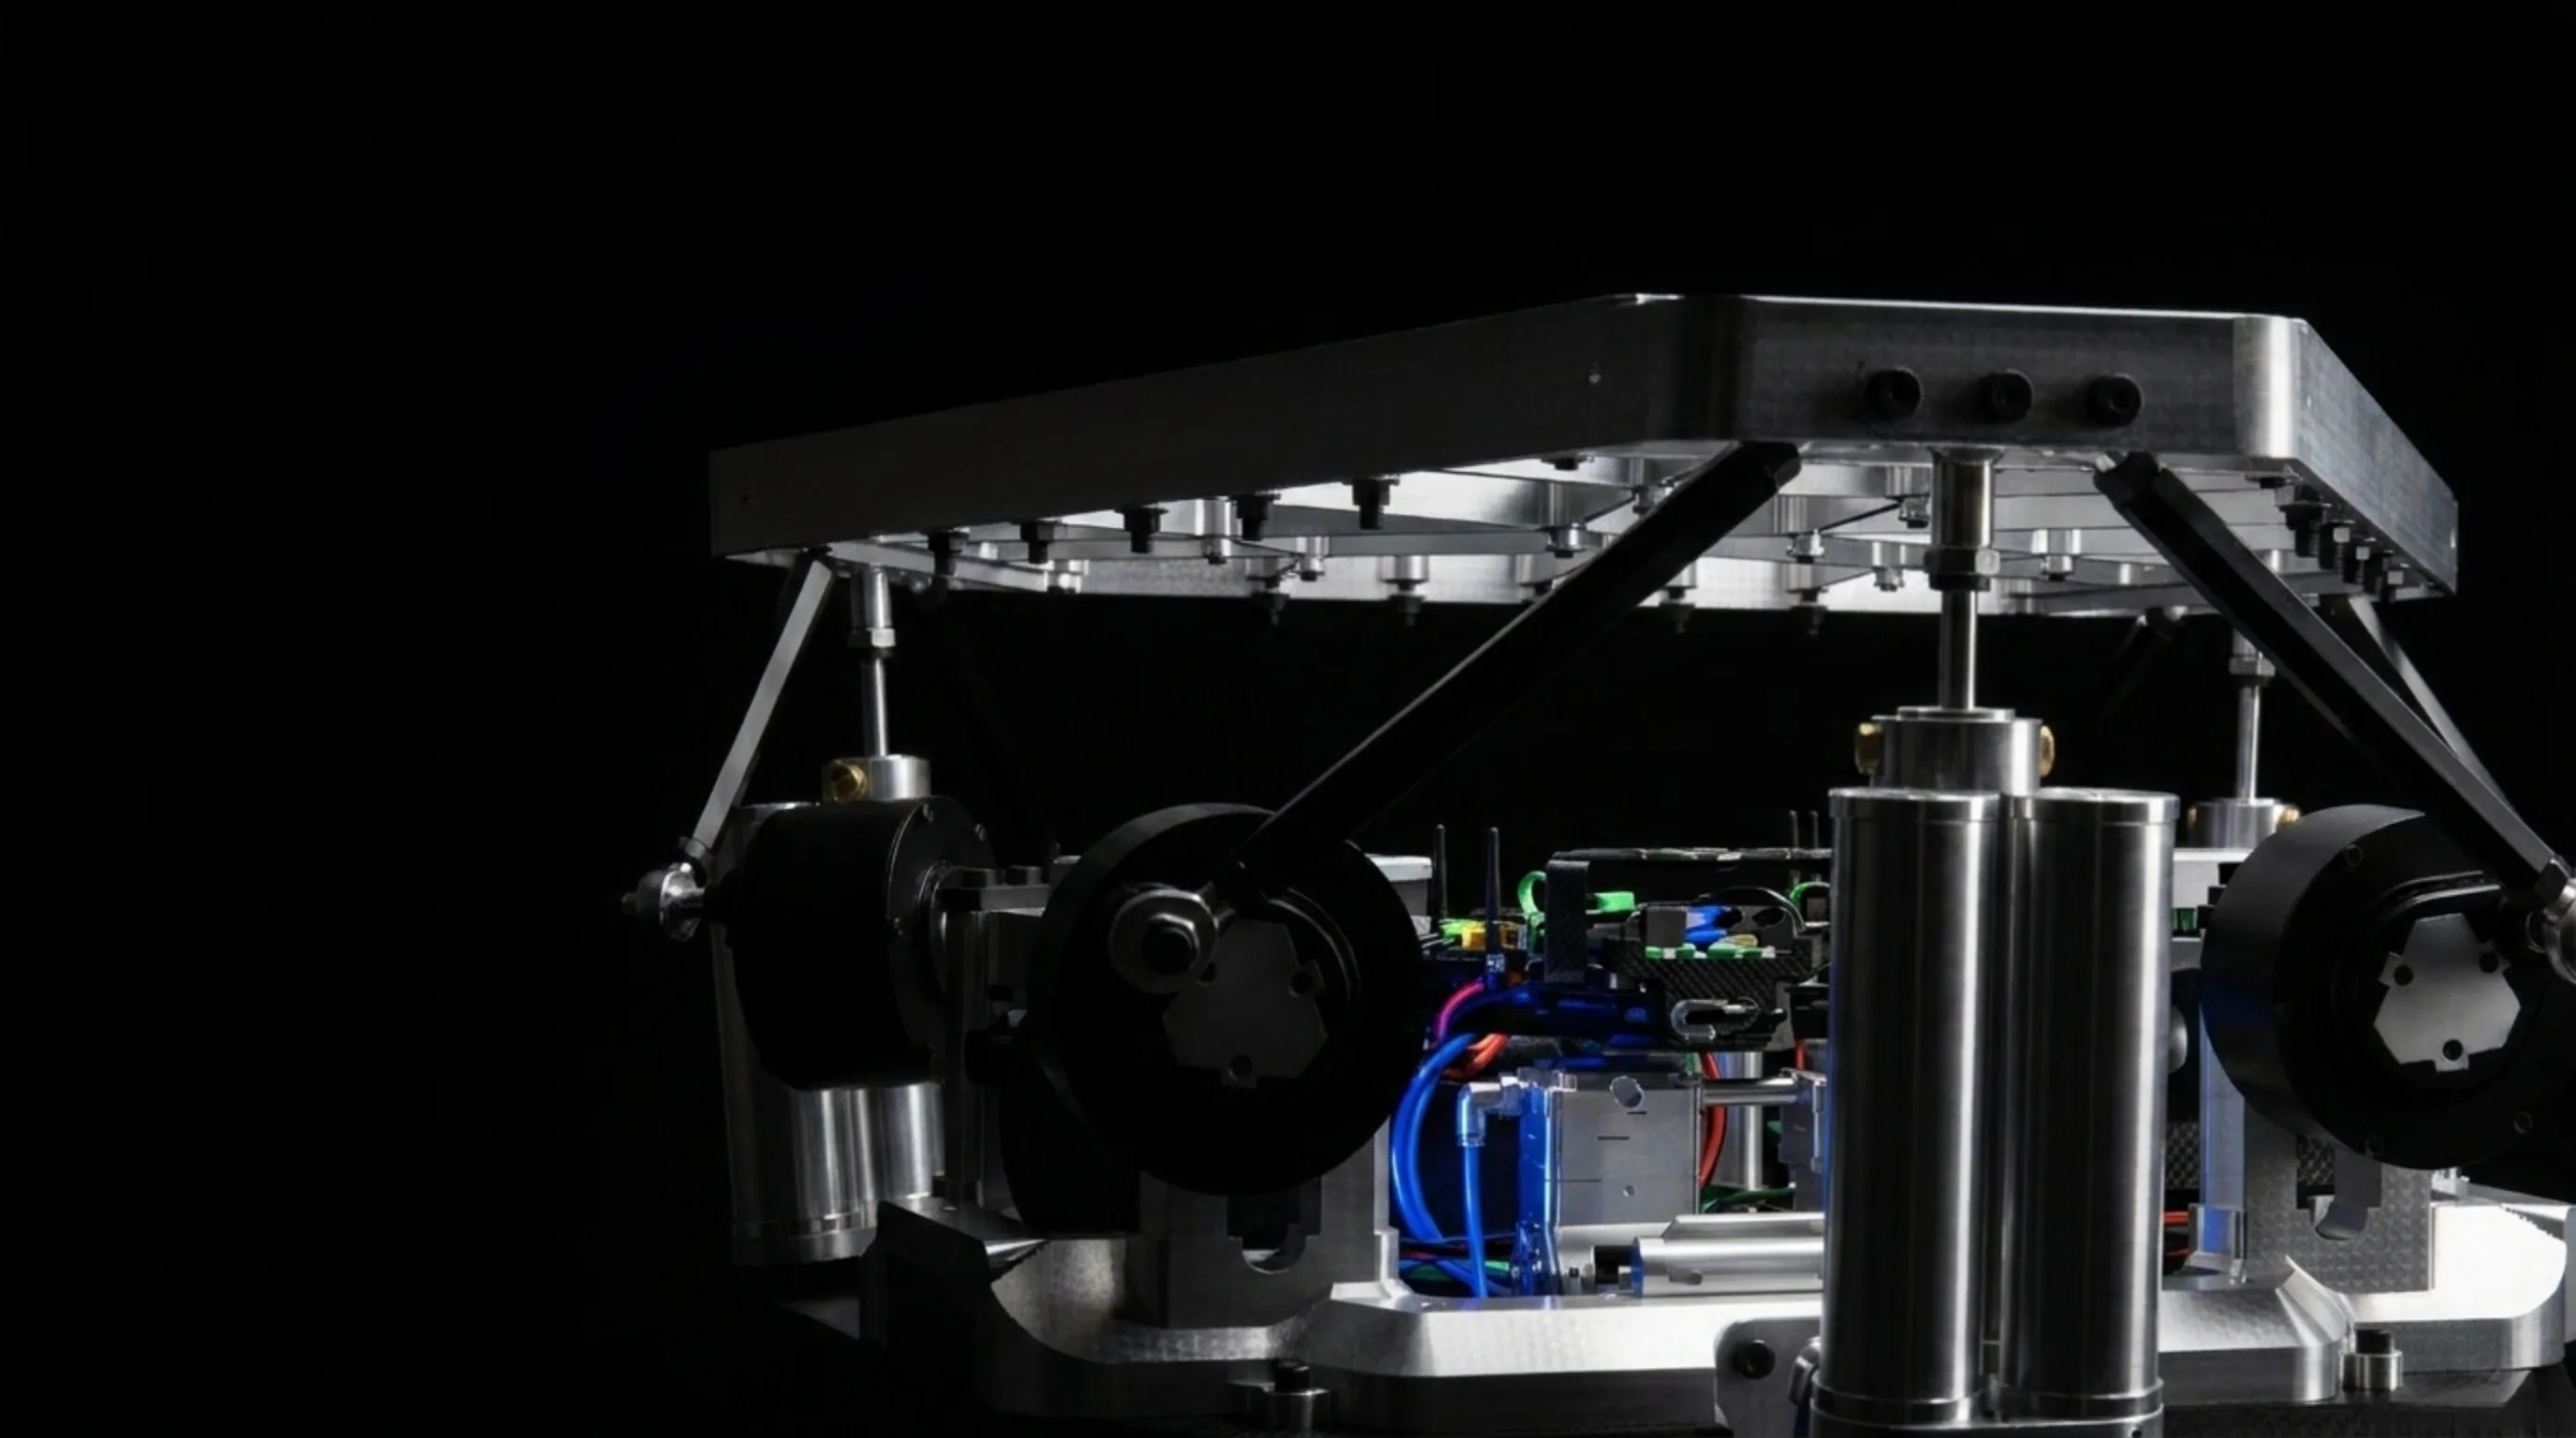
Designed for motion simulation, the Portal Development Kit (PDK) is a six-degree-of-freedom parallel robot built on patented adjustments to the Stewart platform (CA 3217174 C). Direct-drive motors move the legs, pneumatic cylinders carry the static weight, and high-resolution encoders close the loop fast enough that the body reads the result as one event. Under 1 ms and 3 g on all six axes, fully loaded (250 kg). 3 g is the firmware limit on the development kit; the hardware envelope is larger. Development Kit: early-access hardware, software in active development.
Authority
Each carries its source.
independent direct-drive actuators
encoder counts per revolution
drive loop per motor · 125 microseconds
game telemetry to motion
Loop rates are control-loop figures. They are not the rate at which a game or PC receives telemetry from the platform.
Motion
The platform moves along three axes and rotates about three. The PDK uses a right-handed coordinate system. Below, one render takes each axis on its own out to its limit, through to the other and back — scroll to move it.
Every one of the six legs contributes to every one of the six motions. That coupling is what makes a parallel robot stiff and fast — and what makes its control mathematics interesting (see kinematics).
Rendered from the RSCV021 CAD at the single-axis limits in the envelope table. The sweeps are illustrative, not recorded telemetry.
01 · Translation
Front and back, along the longitudinal axis.
02 · Translation
Side to side, along the transverse axis.
03 · Translation
Up and down, along the vertical axis.
04 · Rotation
About the longitudinal axis.
05 · Rotation
About the transverse axis.
06 · Rotation
About the vertical axis.
Actuation
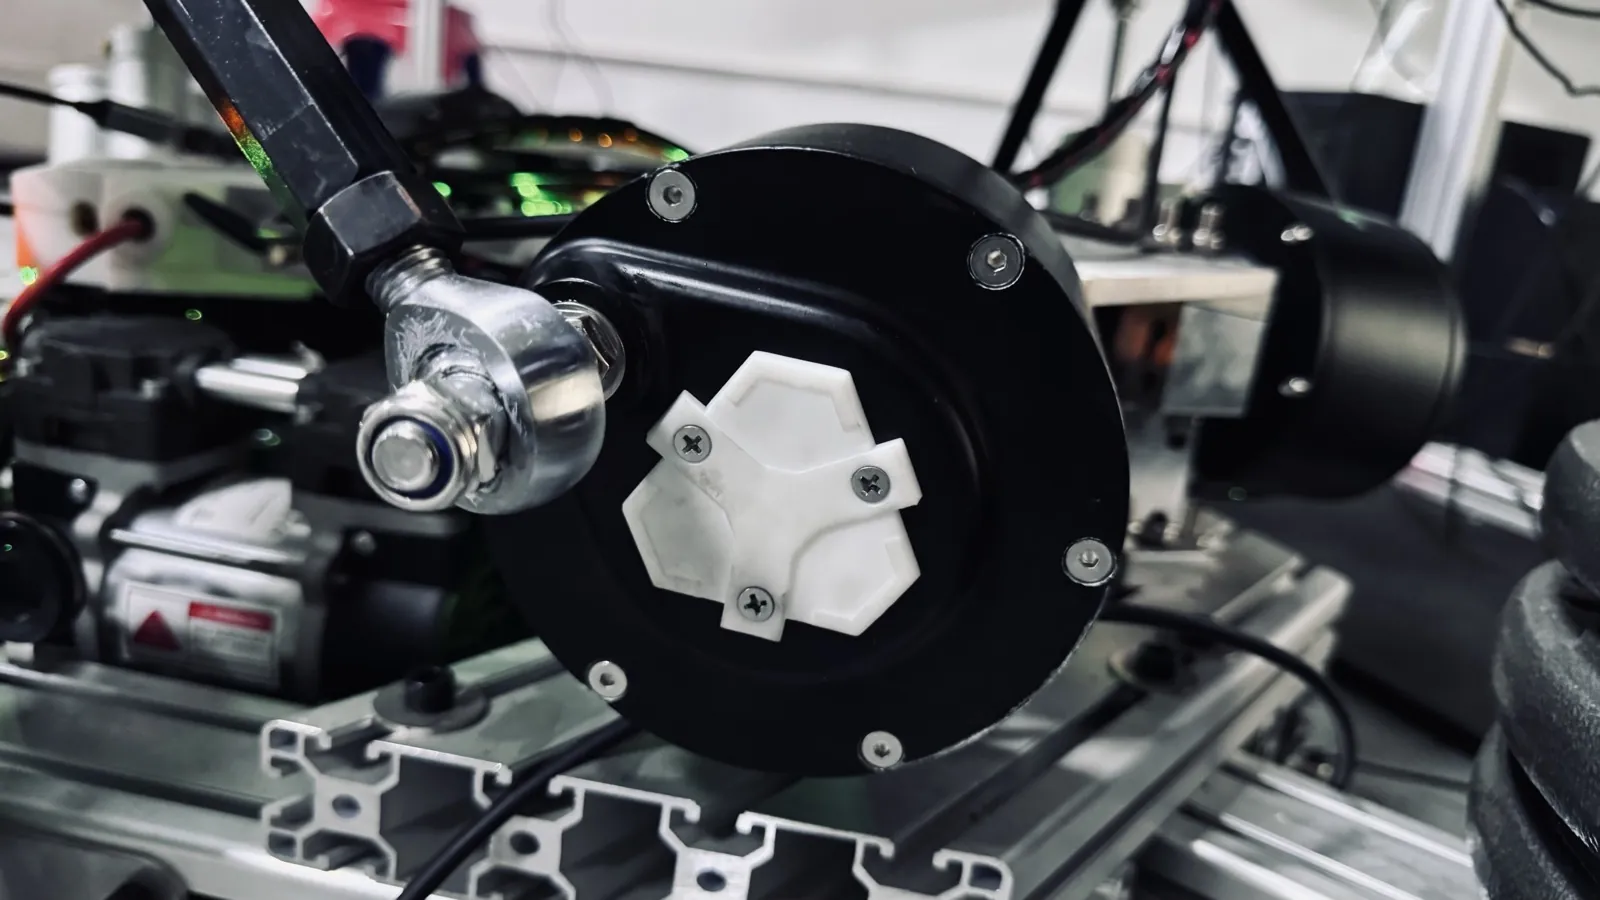
The PDK is a direct-drive 6DOF (DD6DOF) platform. Each leg is driven directly by a high-torque outrunner motor — six custom 132 mm brushless DC motors at 53.3 V, Kv 13.5 — through reinforced shafts and application-specific end plates. There is no belt to stretch, no gearbox to introduce backlash, nothing that wears into play over time. On the RSCV021 build each motor is a cast-aluminum bell on a steel drum with 30 magnet bars, SKF bearings and the 21-bit encoder on a flex PCB.
The consequence for motion fidelity is simple: when the controller asks for a small correction, the platform makes exactly that small correction, immediately, with nothing in between to absorb it.
Feedback
Each motor carries a 21-bit magnetic encoder: 221 = 2,097,152 discrete positions per revolution, or 0.000171661° per count. Encoder data reaches the motor controllers over SPI; the controllers run field-oriented control with integrated PID loops and talk to the system over CAN bus.
Resolution this fine does two things. It lets the controllers correct errors long before they grow into anything you could see or feel, and it gives the platform a positioning repeatability that makes it useful as a research instrument, not only as a simulator.
Per revolution
discrete positions, every motor
per encoder count
SPI to the controllers · CAN to the system
Kinematics
A Stewart platform is a hexapod: six actuators between a fixed base and a moving top. Inverse kinematics — given a desired pose, what length should each leg be? — is straightforward and is solved every cycle to turn a six-dimensional trajectory stream into six joint targets.
Forward kinematics — given six leg positions, where is the platform? — has challenged roboticists for decades because there is no closed-form solution. ARK's solver makes it fast enough to use in the loop.
| Forward kinematics | Figure | Source |
|---|---|---|
| Random pose calculation | 207 µs average | ARK engineering record |
| Sequential pose processing | 109 µs (≈9,174 / s) | ARK engineering record |
| Arithmetic precision | double, 1 × 10⁻¹⁴ | ARK engineering record |
| GPU throughput (Nvidia Quadro M6000) | > 1,200,000 / s | ARK engineering record |
Fast forward kinematics opens the door to task-space control architectures — controlling the platform in the coordinates the rider feels, rather than only in leg lengths. Today the motion control runs in joint space: six independent linear controllers in a decentralised PID structure, each fed by its own high-resolution encoder, at an 8,000 Hz loop on two ARM Cortex-M7 processors at 600 MHz.
Patented
Holding a person and a platform up against gravity is constant work. If the motors do it, they spend most of their thermal budget standing still. The PDK instead carries the static load on air: three pneumatic cylinders (50 mm bore, 140 mm stroke, up to 6.0 bar) with dual dead-volume tanks per cylinder, an integrated compressor and a 10-station valve manifold, and automatic load monitoring that re-balances as the payload changes.
With gravity negated, the platform floats. The motors then handle only the difference between where the platform is and where the trajectory wants it — which is why a 15 W static hold and a 30 kW burst can live in the same one-square-metre machine.
static hold, platform up
burst, on demand
maximum cylinder pressure
Comparison
Belt, gear and actuator rigs against the PDK, property by property.
| Property | Belt / gear / actuator platforms | PDK |
|---|---|---|
| Transmission | Belts, gears or ball screws — backlash and wear | Direct drive — no intermediate transmission |
| Static load | Carried by the actuators (heat, derating) | Carried pneumatically (15 W hold) |
| Position feedback | Typically 14 bit | 21 bit (2,097,152 counts) |
| Motion bandwidth | 20–100 Hz typical | 1 kHz. Vibration up to 629 Hz, measured with up to 250 kg on board · up to 2,000 Hz on each independent motor. See direct drive. |
| Footprint | Varies; often > 2 m² | 1.00 × 1.00 m; 1.57 m in diameter with the extension feet |
| Energy path | Braking energy dumped as heat | Capacitor bank recirculates braking energy |
The "conventional" column describes typical consumer and prosumer motion rigs and is illustrative, not a claim about any named product.
Envelope
One envelope is published: the single-axis limit of each axis, with every other axis at neutral. The axes trade against each other, so no axis reaches its limit while the others are working. A combined-axis extended envelope is larger and real, but it is not published — see the note below the table.
The gauges show the motion envelope on one shared scale; the table beneath carries it axis by axis, with the source for every figure.
| Axis | Range | Total span | Source |
|---|---|---|---|
| Surge | −75.49 … +82.74 mm | 158.23 mm | T1 boot banner |
| Sway | ± 71.92 mm | 143.85 mm | T1 boot banner |
| Heave | ± 58.68 mm | 117.35 mm | T1 boot banner |
| Pitch | −7.98° … +8.09° | 16.07° | T1 boot banner |
| Roll | ± 8.68° | 17.36° | T1 boot banner |
| Yaw | ± 9.80° | 19.60° | T1 boot banner |
All six figures are read from the T1 firmware boot banner, 2026-07-07 capture. The firmware carries no envelope literals: it computes its limits at boot from the platform geometry and refuses an out-of-envelope pose. A combined-axis “extended” envelope is larger, and it is published when it is measured.
Specifications
| Architecture | Stewart platform · six independent direct-drive actuators · patented adjustments (CA 3217174 C) |
|---|---|
| Control | Joint-space decentralised PID · 1 kHz game to motion · 3.3 kHz control loop · drive commands at 2.5 kHz or more per drive, 3.3 kHz preferred · 8,000 Hz field-oriented control (FOC) per motor · 2 × ARM Cortex-M7 @ 600 MHz |
| Feedback | 6 × 21-bit magnetic encoders · SPI to controllers · CAN bus system link |
| Drives | 3 × dual-channel BLDC controllers · 53.3 V · 56 A per motor channel to the ArkDrive · field-oriented control |
| Load compensation | 3 × pneumatic cylinders 50 mm × 140 mm · 6.0 bar max · automatic load balancing |
| Power | Universal auto-switching PSU, 100–290 V AC: 3,000 W on 200–290 V, 1,400 W on 100–130 V · 3 × 63 V 0.47 F capacitor bank · >30 kW burst · 15 W static hold |
| Feet | Recycled rubber |
| Safety | 2 × mmWave presence radars standard · up to 6 for 360° coverage · emergency stop |
| Footprint | 1.00 × 1.00 m platform · 1.57 m in diameter with the extension feet · retracted height 0.50 m |
Questions
Yes. Maglev is our name for the technology that makes the platform feel weightless: per-axis friction and gravity compensation maps in the drive firmware, measured on the wheel at 0.00435 N·m against a 0.005 N·m pass mark. They ride on pneumatic compensators and direct-drive motors. The air carries the mass, the motors move it, and the maglev maps make it feel frictionless.
No. Your game sends at its own rate, typically 60 Hz. The PDK turns that into motion 1,000 times a second (1 kHz game to motion), and each update has the platform moving in under a millisecond. Inside the platform, the control loop runs at 3.3 kHz and each motor's field-oriented control at 8 kHz. None of these is a telemetry rate to your PC or game.
Around every pose the platform can reach. The single-axis figures on the technology page are the motion envelope, and combined moves reach further, so leave clearance beyond them.
Because it lets the controller reason in the rider's coordinates — surge, sway, heave and the rotations — instead of only in leg lengths. That is the foundation for task-space control and for reporting where the platform actually is.
Provenance
Patent CA 3217174 C — Canadian Intellectual Property Office. Granted 11 February 2025; the grant and the official register entry are linked from Patents.
Encoder arithmetic: 221 = 2,097,152; 360° ÷ 2,097,152 = 0.000171661°. Verified by calculation.
Latency, bandwidth, envelope, forward-kinematics timings and power figures: ARK engineering record, as published on ark-dynamics.com
Energy-recirculation framing: ARK engineering record.
Deeper reading
This page is the overview. Each of these takes one part of the architecture and states what it does, what it costs, and where the number comes from.
No gearbox, no belt, no ballscrew — what that removes from the load path, and what it asks of the motor instead.
The dead zone at every reversal, and why a platform meets it far more often than a machine tool does.
2,097,152 positions per revolution, absolute, read on every drive cycle.
Smooth torque at any shaft angle, recomputed 8,000 times a second on every motor.
Three nested loops at three rates, and a clear account of what closing a loop cannot fix.
Six legs in parallel rather than six axes stacked, and what that geometry costs.
Air carries the standing load so the motors do not — plus one published claim we will not repeat.
Metres of travel, kilometres of road. Where a motion platform is really won or lost.
What talks to the platform, how, and a clear statement of whose software each tool actually is.
Two endpoints or it is not a measurement. Under 1 ms, game telemetry in, motion out, with both points stated.
The PDK + ARK Ecosystem development kit finishes it: racing chassis, ARK direct-drive wheelbase, wheel, load-cell pedals and button box, matched and tuned as one system. You add the seat, PC, screen and games.
Built in sequence for qualified recipients: ready to ship an estimated 3–6 months from order confirmation